Klaus Weber
Technische Universität Cottbus,
Lehrstuhl Numerische und Angewandte Mathematik
There are many approaches that use artificial neural networks (ANNs) for adaptive control of dynamical processes. It was shown that prestructuring of ANN may improve their performance and allow their interpretability. The paper sketches an hybrid attempt, an adaptive neuro-fuzzy control system, and surveys three different kinds of neural defuzzification elements. Since they are located at the transition between controller and model of the process, they should not only be capable of proper defuzzification (other papers deal with this aspect, e.g. [11]) but also to backpropagate an output error. I show, that only one of them manages this task well.
Adaptive neural control systems, using feedforward ANNs, may consist of two parts: a neural controller and a neural model of the process to be controlled [7], [9]. The process model is necessary to indicate changes of the process, and through its neural implementation it is possible to backpropagate an adequate error measure to the neural controller and to update its weights.
There are several methods to prestructure an ANN: Some are suited to a single application [12], [3], some recent approaches use wavelets [2], [8] and many make use of fuzzy rules. They have all in common, that they use a priori knowledge on the process to be controlled. There are prestructuring methods that use standard components of ANNs (sigmoid or RBF units [10], [8]) as well as special processing elements, like "wavelons" [13] or neurons with incorporated t-Norms [4].
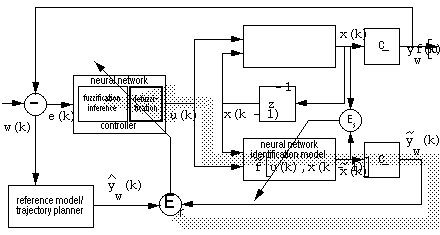
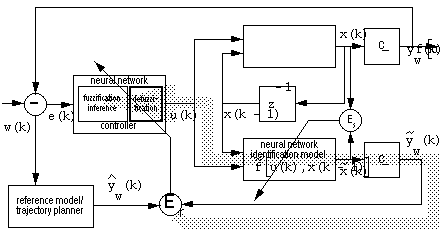
In my paper I use a technique of predesigning ANNs that represents a fuzzy set by a discrete set of elements and their attached degrees of membership, and represents them by neurons and their activation respectively. A draft of an adaptive control system based on this technique is shown in figure 1. It is similar to already known state-room schemes, except for the defuzzification component. As it is shown by the grey arrow, this component does not only defuzzify the controller's output but also has to backpropagate the system's output error.
Three neural defuzzification methods where examined on their capability
of "backpropagation": The so called "thermometer encoding"
and two approaches that regard defuzzification as a mapping. Accordingly
with the chosen prestructuring technique, neurons with a sigmoid function
 are
used.
The "thermometer encoding" [3]
is based on comparisons of the fuzzy set's membership degrees. In orderto achieve sharp comparison boundaries, the weights leading to a "comparison
neuron" are quite high in amount, or, what is the same, the exponent
in the sigmoid's denominator takes only amounts that lie in the saturated
domain of  .
In fact, the sigmoid function is squeezed to a treshhold function. Since
the change of weights depends on factors
 an output error will not be backpropagated.
It is well known that a backpropagation network with one hidden layer
can approximate a given continuous mapping  up to an arbitrary degree of accuracy, depending on the number of hidden
units [1], [5].
A constructive proof of this claim is given in [6].
Since defuzzification by the centre of area method is such a mapping, this
approach may be adequate. It is shown, that this method, like the "thermometer
encoding", is based on "squeezing" sigmoid functions, i.e.
using treshhold functions. Therefore the backpropagation also fails.
At last, the mapping  was simply trained by an ANN. The resulting neural defuzzification showed
an excellent backpropagation quality.
In conclusion it may be stated that all neural defuzzification methods, that are based on "squeezed" sigmoid units (=treshhold units), are not capable of backpropagating errors. A trained centre of area mapping showed good properties, but they are only experimental and not theoretically proven. However, this is the way for further investigation.
figure 1: